
Top
Design Stability Into the Architecture, Not Into Operations
We design the systemic production behavior so that flows remain synchronized, variation does not amplify instability, and production remains predictable under real operating conditions. Because uptime does not mean stability.
01 Change the Paradigm
In Modern Manufacturing, Automation Has Increased Performance — But Not System Stability
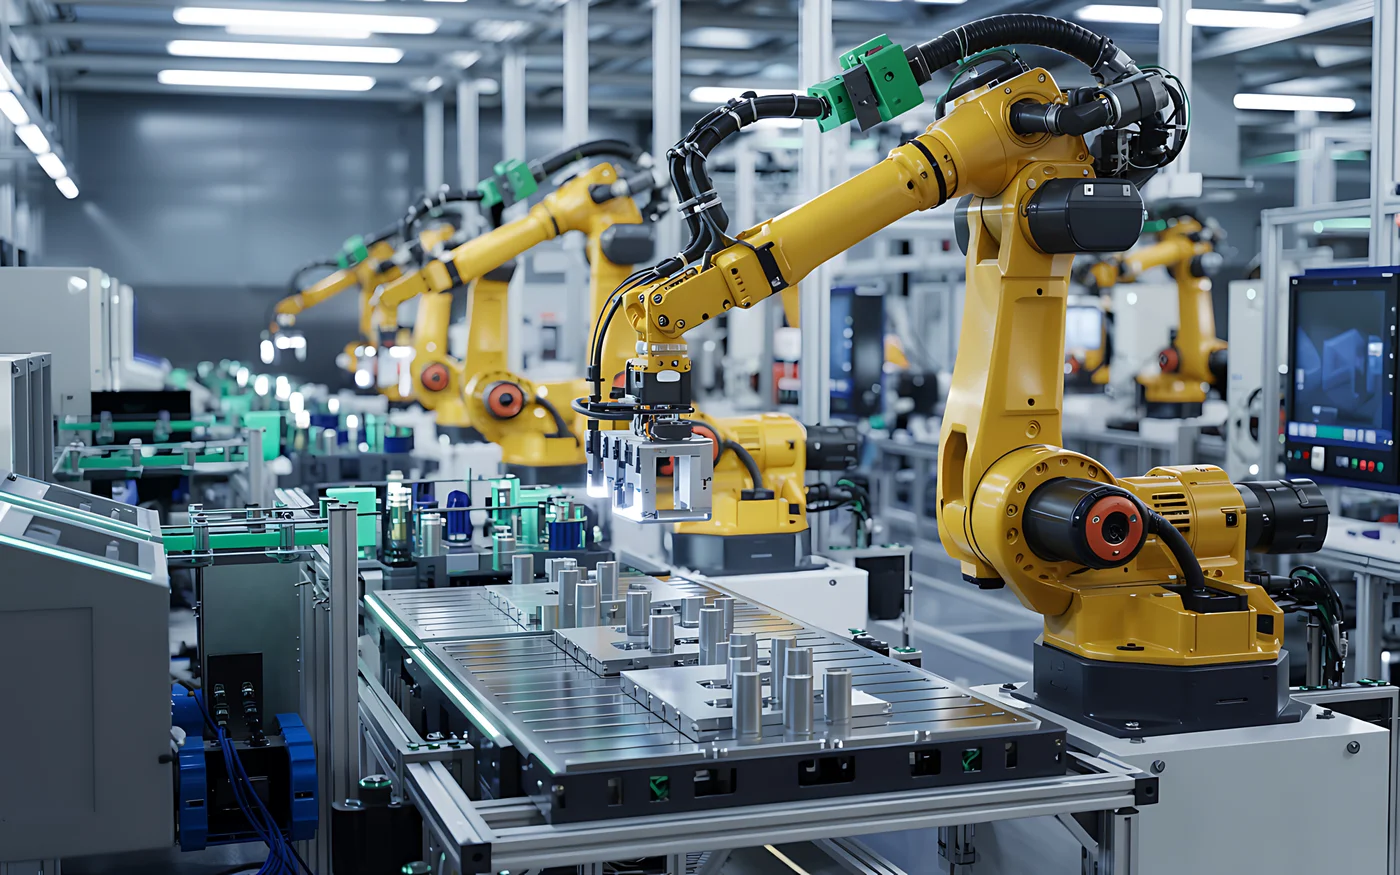
Modern manufacturing plants are faster, more connected, and more automated than ever before.
Automation has increased speed, digitalization has increased visibility, and AI is enabling more advanced optimization.
The machines work, but complexity is growing faster than the plant’s ability to control it. This leads to:
- Recurring interventions
- Hard-to-predict downtime
- Quality variation
- Performance losses
- Difficult scaling
- Dependence on individual expertise
ADOPT THE NEW ENGINEERING STANDARD
![]()
Stability Is of Property of Systems, Not Equipment
RCE treats industrial production as an architecture of interdependent systems, not as a linear chain of equipment. Instead of focusing exclusively on the performance of each machine, we design the conditions that determine how the systems operate together.
INTERACTION STRUCTURE

We analyze the relationships between processes, resources, and systems to identify hidden sources of instability.
INTERACTION STRUCTURE
VARIATION PROPAGATION

We analyze variation propagation and eliminate cascading effects, instability, and degradation of operational performance.
VARIATION PROPAGATION
EVOLUTION OF OPERATIONAL STATES
We monitor system evolution under changing loads, conditions, and disturbances, and anticipate state transitions.
EVOLUTION OF OPERATIONAL STATES
FEEDBACK AND PERFORMANCE
We analyze the feedback loops that amplify or stabilize systems. We increase robustness and adaptability.
FEEDBACK AND PERFORMANCE
SYSTEM BEHAVIOR

We study emergent patterns that influence production stability, resilience, and predictability.
SYSTEM BEHAVIOR
We Design the Interactions

We design interactions between equipment and processes to prevent undesirable emergent behavior at system level.
Result: we eliminate the effects of emergent instability and reduce error propagation between subsystems.
We Synchronize Flows

We synchronize material, information, and process flows to eliminate imbalances that generate production instability.
Result: stable flows, fewer bottlenecks, and more consistent throughput.
We Manage Variability

We define how the system responds under operational load so that performance remains stable under real conditions.
Result: sustained stability across changing load levels and high performance even under stress.
We Design Feedback

We build mechanisms through which the system can detect, interpret, and correct deviations before they affect performance.
Result: greater capacity to anticipate and absorb operational deviations, fewer production surprises, and performance maintained within predictable limits.
Stability Is Measurable
In industry, instability is often treated reactively. RCE models it systematically.


 Our Projects
Simple on the outside. Highly intelligent on the inside.







 Talk to an Engineer
Build Stable Systems Under Variable Conditions
